

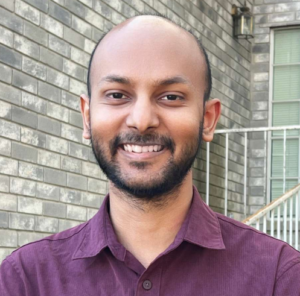
VSCL is proud to welcome two new graduate research assistants:
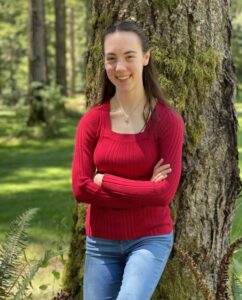 Evelyn Madewell joins VSCL as a Ph.D student in the Aerospace Engineering department. She graduated in the Spring of 2024 from the University of Washington with a BS in Aeronautical & Astronautical Engineering and a Minor in Applied Mathematics. As an undergraduate, she was a research assistant and test pilot in the Autonomous Flight Systems Lab. Her research background includes wilderness search and rescue, hazard aware landing optimization, and beyond visual line of sight operations, which she presented at the 2024 AIAA SciTech Forum. Evelyn has interned with Freefly Systems as a flight test engineer, where she programmed a novel testing procedure for the Astro commercial drone platform, and is currently investigating Sequential Triangulation as a way of solving 3D visual navigation in GPS-denied scenarios with Hood Technology. With her interest in flight test engineering and UAV controls, Evelyn’s work with VSCL will begin by contributing to the Real-time System Identification of UAS project.”
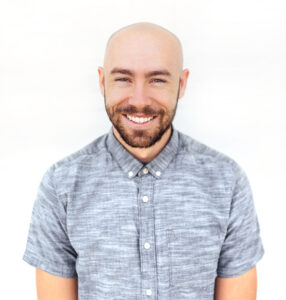 Zach Curtis is graduated from Utah Tech with a bachelor’s in mechanical engineering in 2024. Throughout his undergraduate years, he pursued various internships to broaden his practical experience. At RAM Aviation Space & Defense, he interned within the Finite Element Analysis (FEA) group, the prototyping lab, and the controls engineer group, gaining insights into different facets of mechanical engineering. Additionally, he had the opportunity to intern at Baxter Aerospace, a consulting group, where he worked as a mechanical engineer specializing in designing liquid nitrogen baths for application in nuclear fusion research. Furthermore, during his junior year he engaged in research activities at Utah Tech under the guidance of PhD Monty Kennedy, focusing on Shock and Vibration testing. This involved utilizing the NASA-sponsored Shock Sat testing device to contribute to the advancement of knowledge in the field of shock testing on spacecraft.
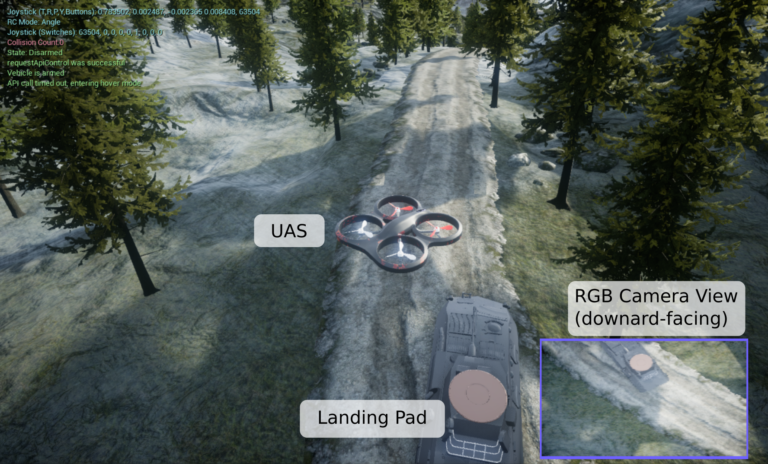
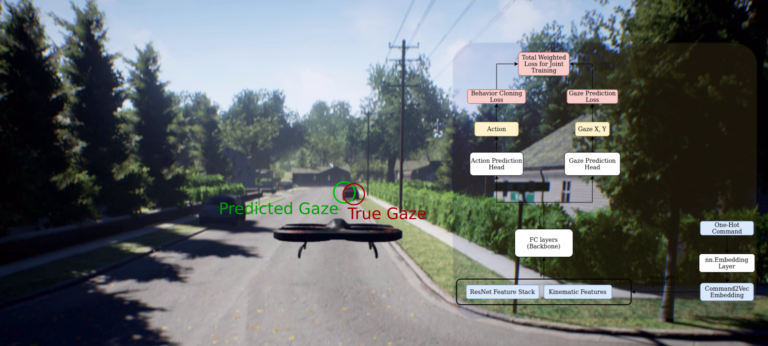
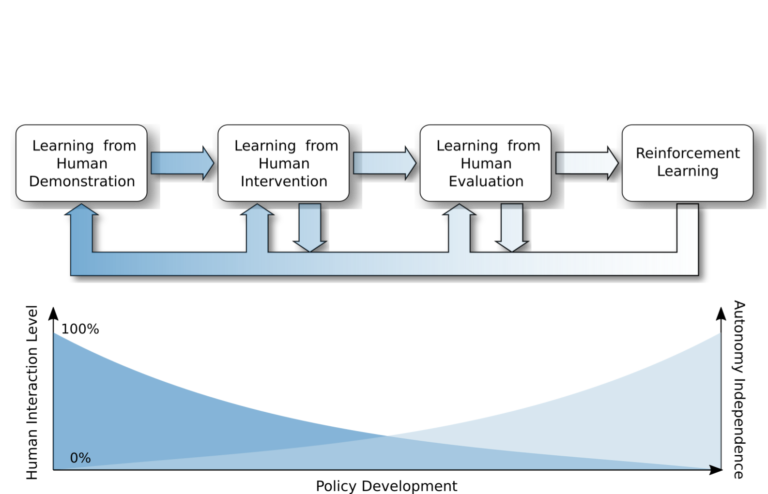
 Approaches for teaching learning agents via human demonstrations have been widely studied and successfully applied to multiple domains. However, the majority of imitation learning work utilizes only behavioral information from the demonstrator, i.e. which actions were taken, and ignores other useful information. In particular, eye gaze information can give valuable insight towards where the demonstrator is allocating visual attention, and holds the potential to improve agent performance and generalization. In this work, we propose Gaze Regularized Imitation Learning (GRIL), a novel context-aware, imitation learning architecture that learns concurrently from both human demonstrations and eye gaze to solve tasks where visual attention provides important context. We apply GRIL to a visual navigation task, in which an unmanned quadrotor is trained to search for and navigate to a target vehicle in a photo-realistic simulated environment. We show that GRIL outperforms several state-of-the-art gaze-based imitation learning algorithms, simultaneously learns to predict human visual attention, and generalizes to scenarios not present in the training data.
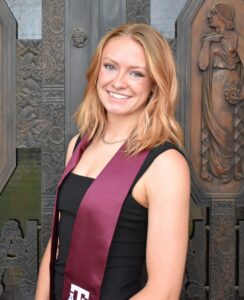 selected by the AERO Graduate Program Committee with an award of $1,000.